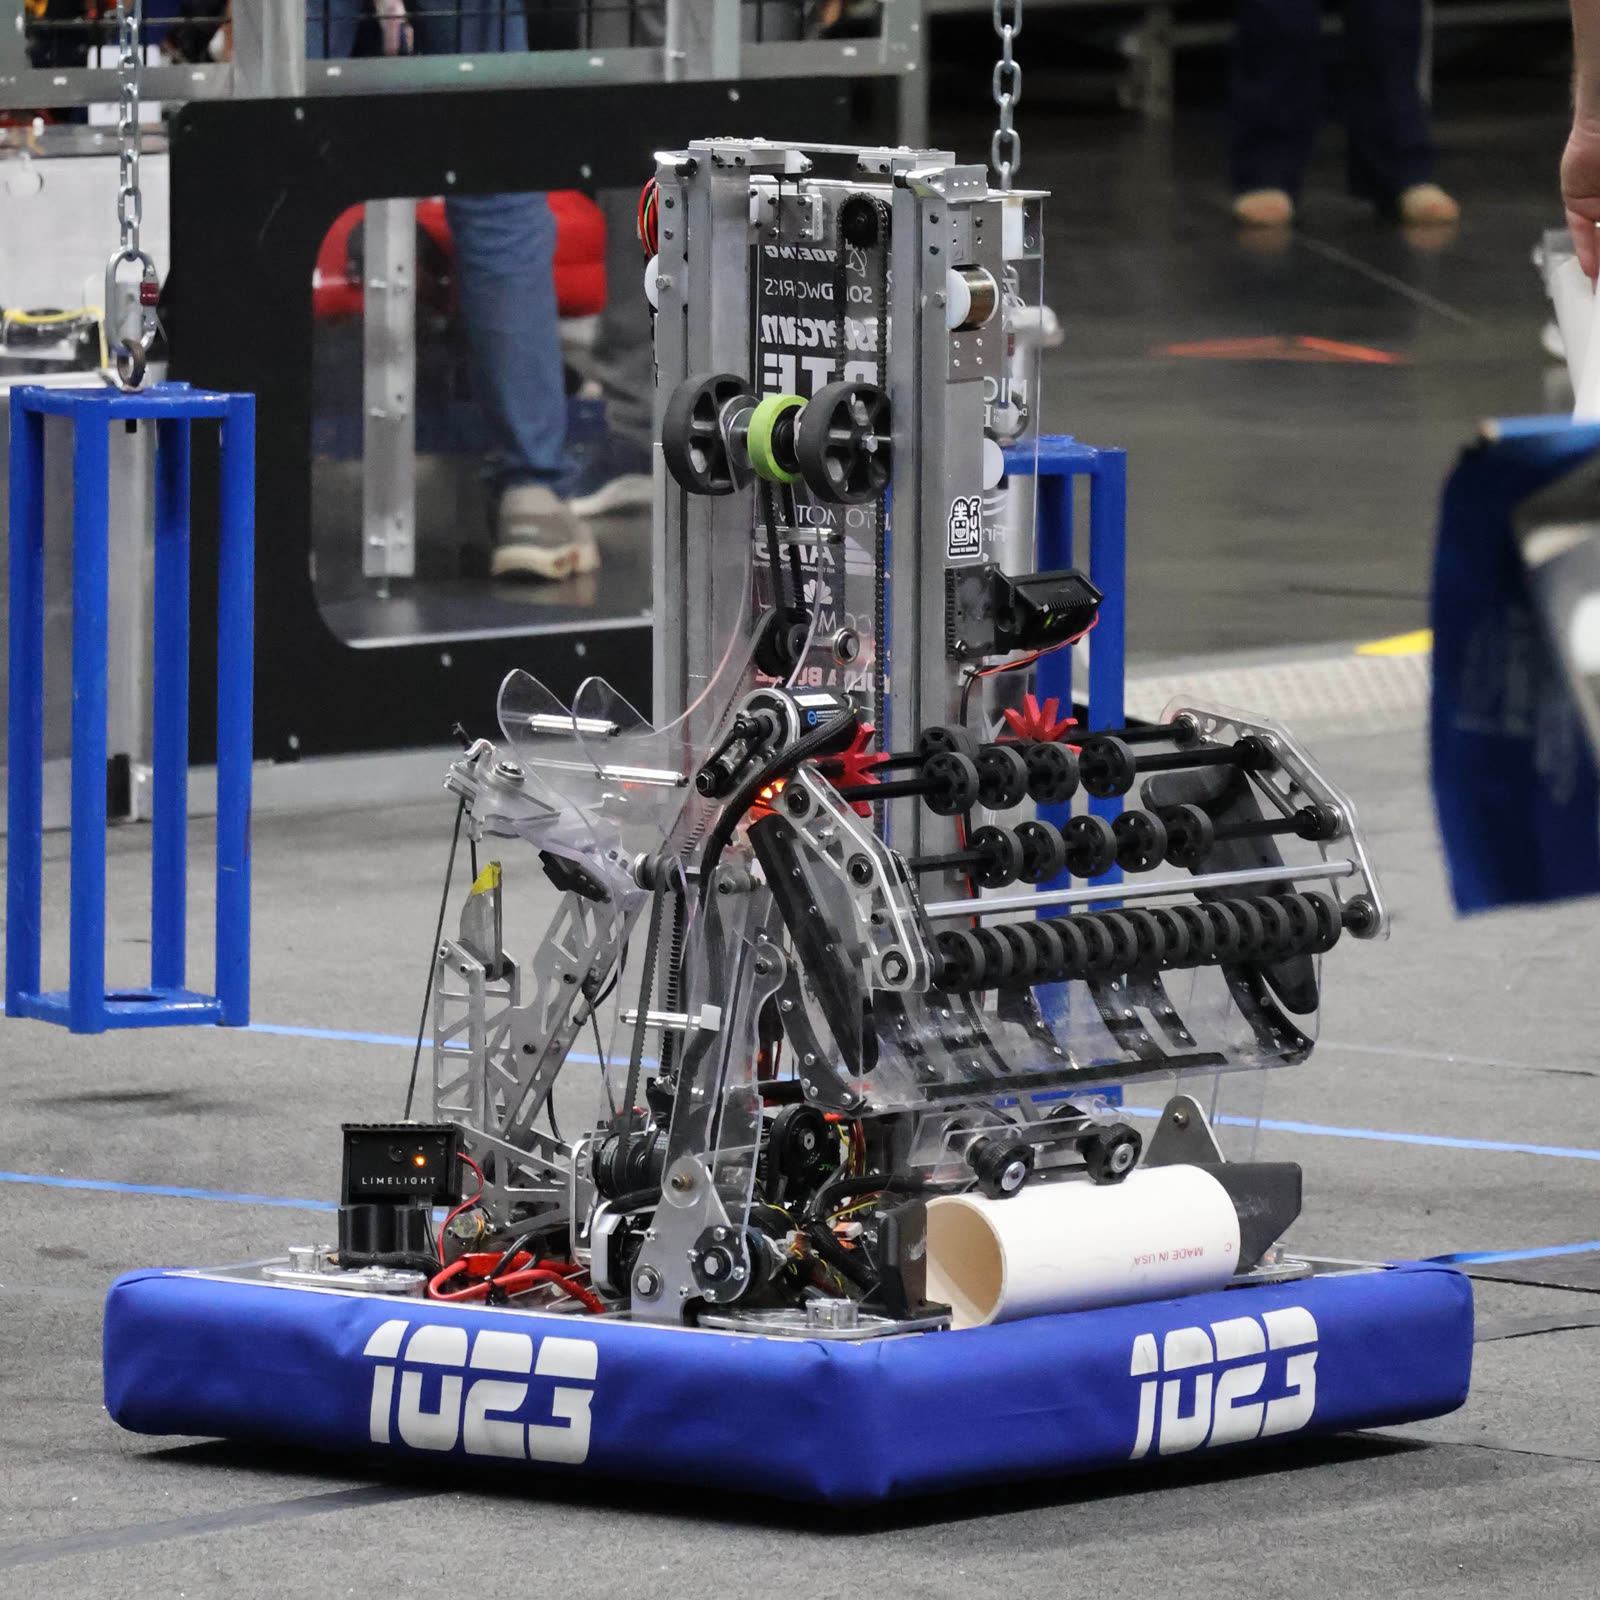
A 4-bar linkage ground intake for our FRC team's 2025 season robot, built to pick up and orient game pieces smoothly under the frame.
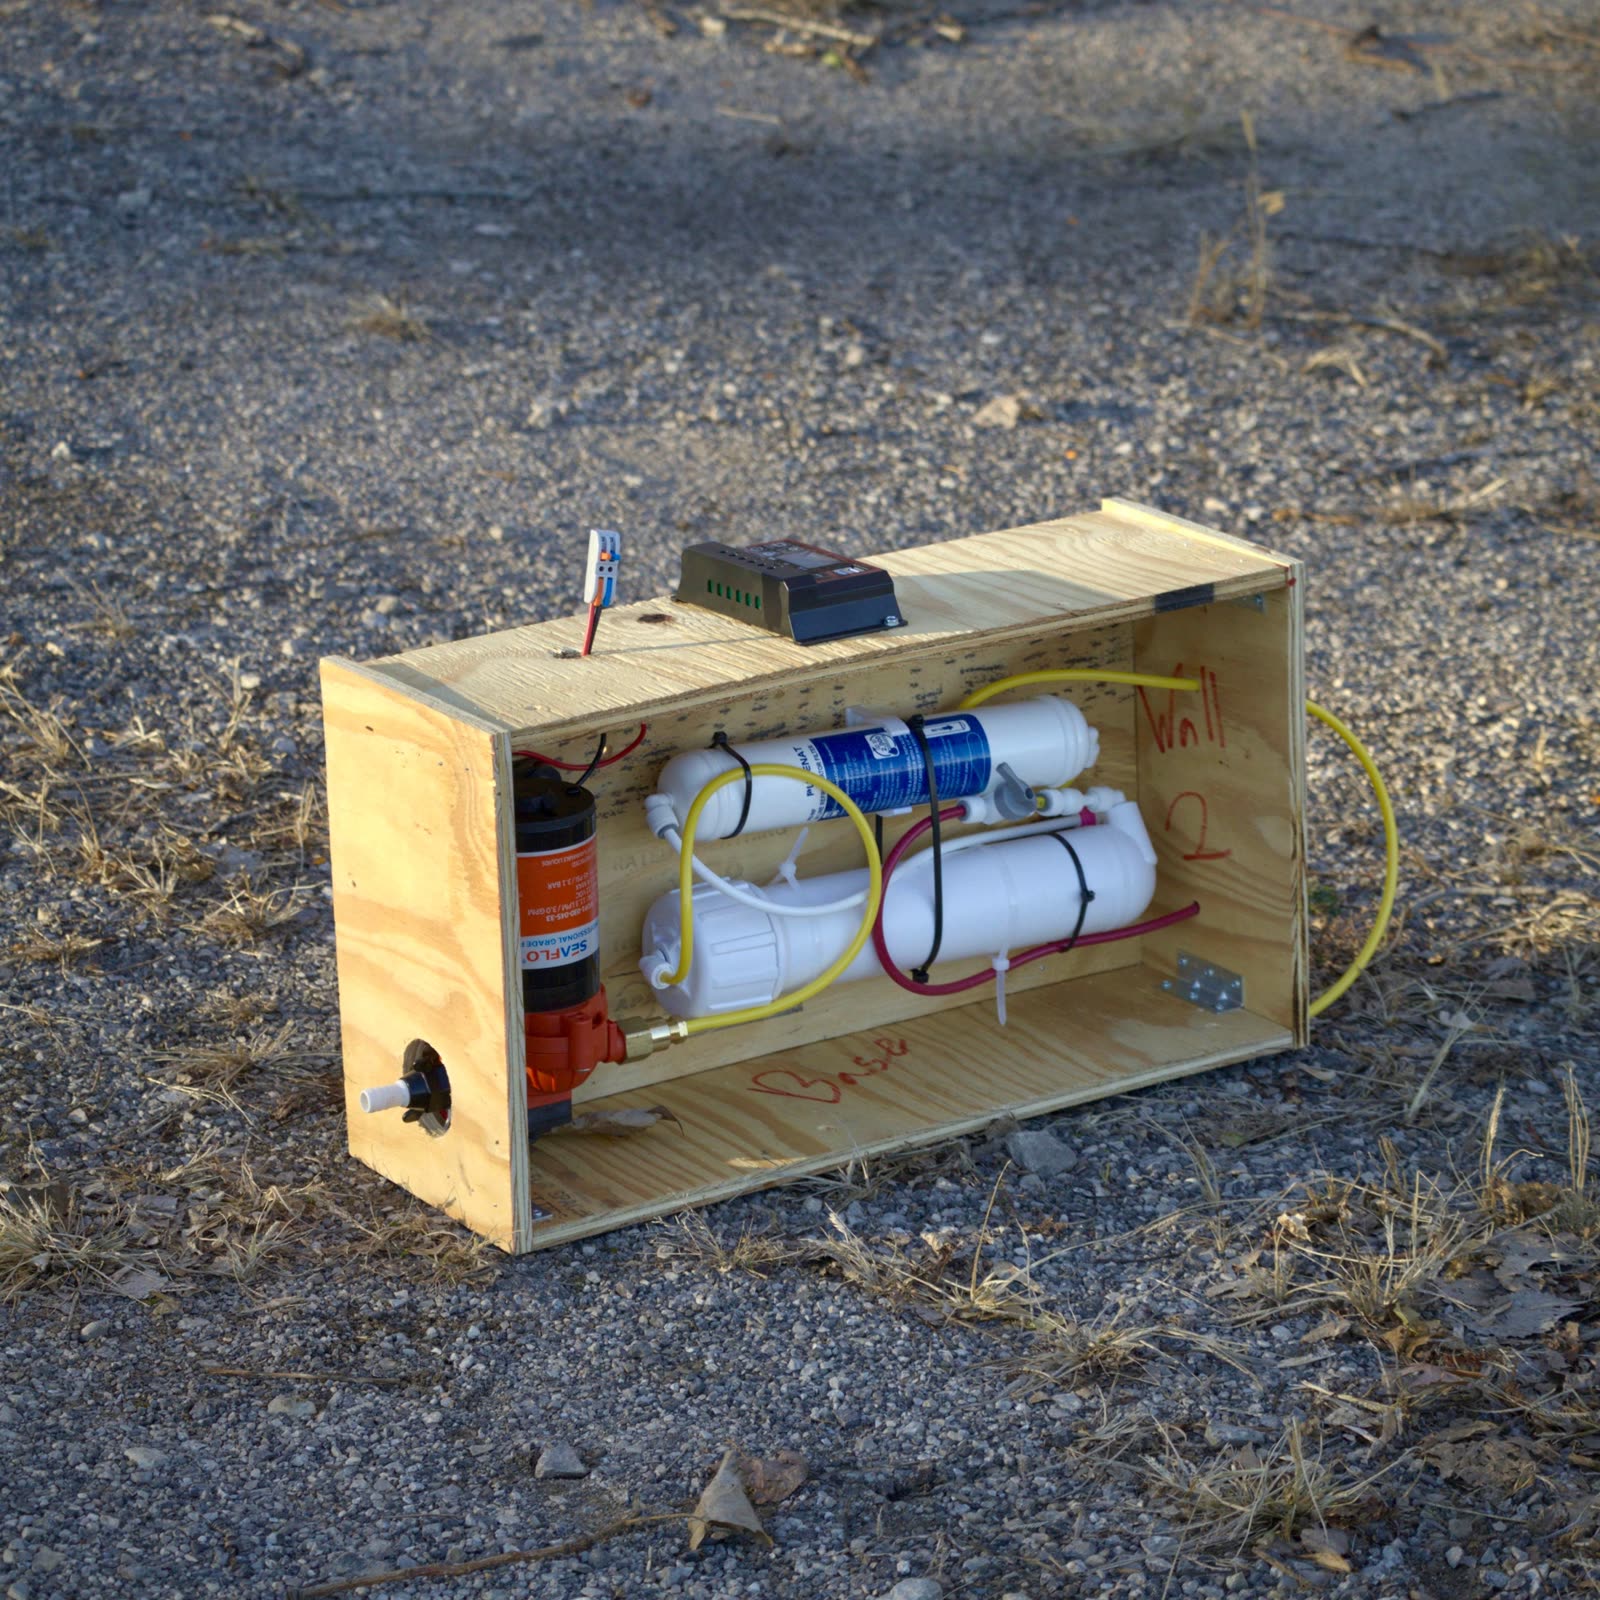
A reverse-osmosis water filtration system built with a group at the University of Toledo to tackle the grand challenge of accessing clean water.
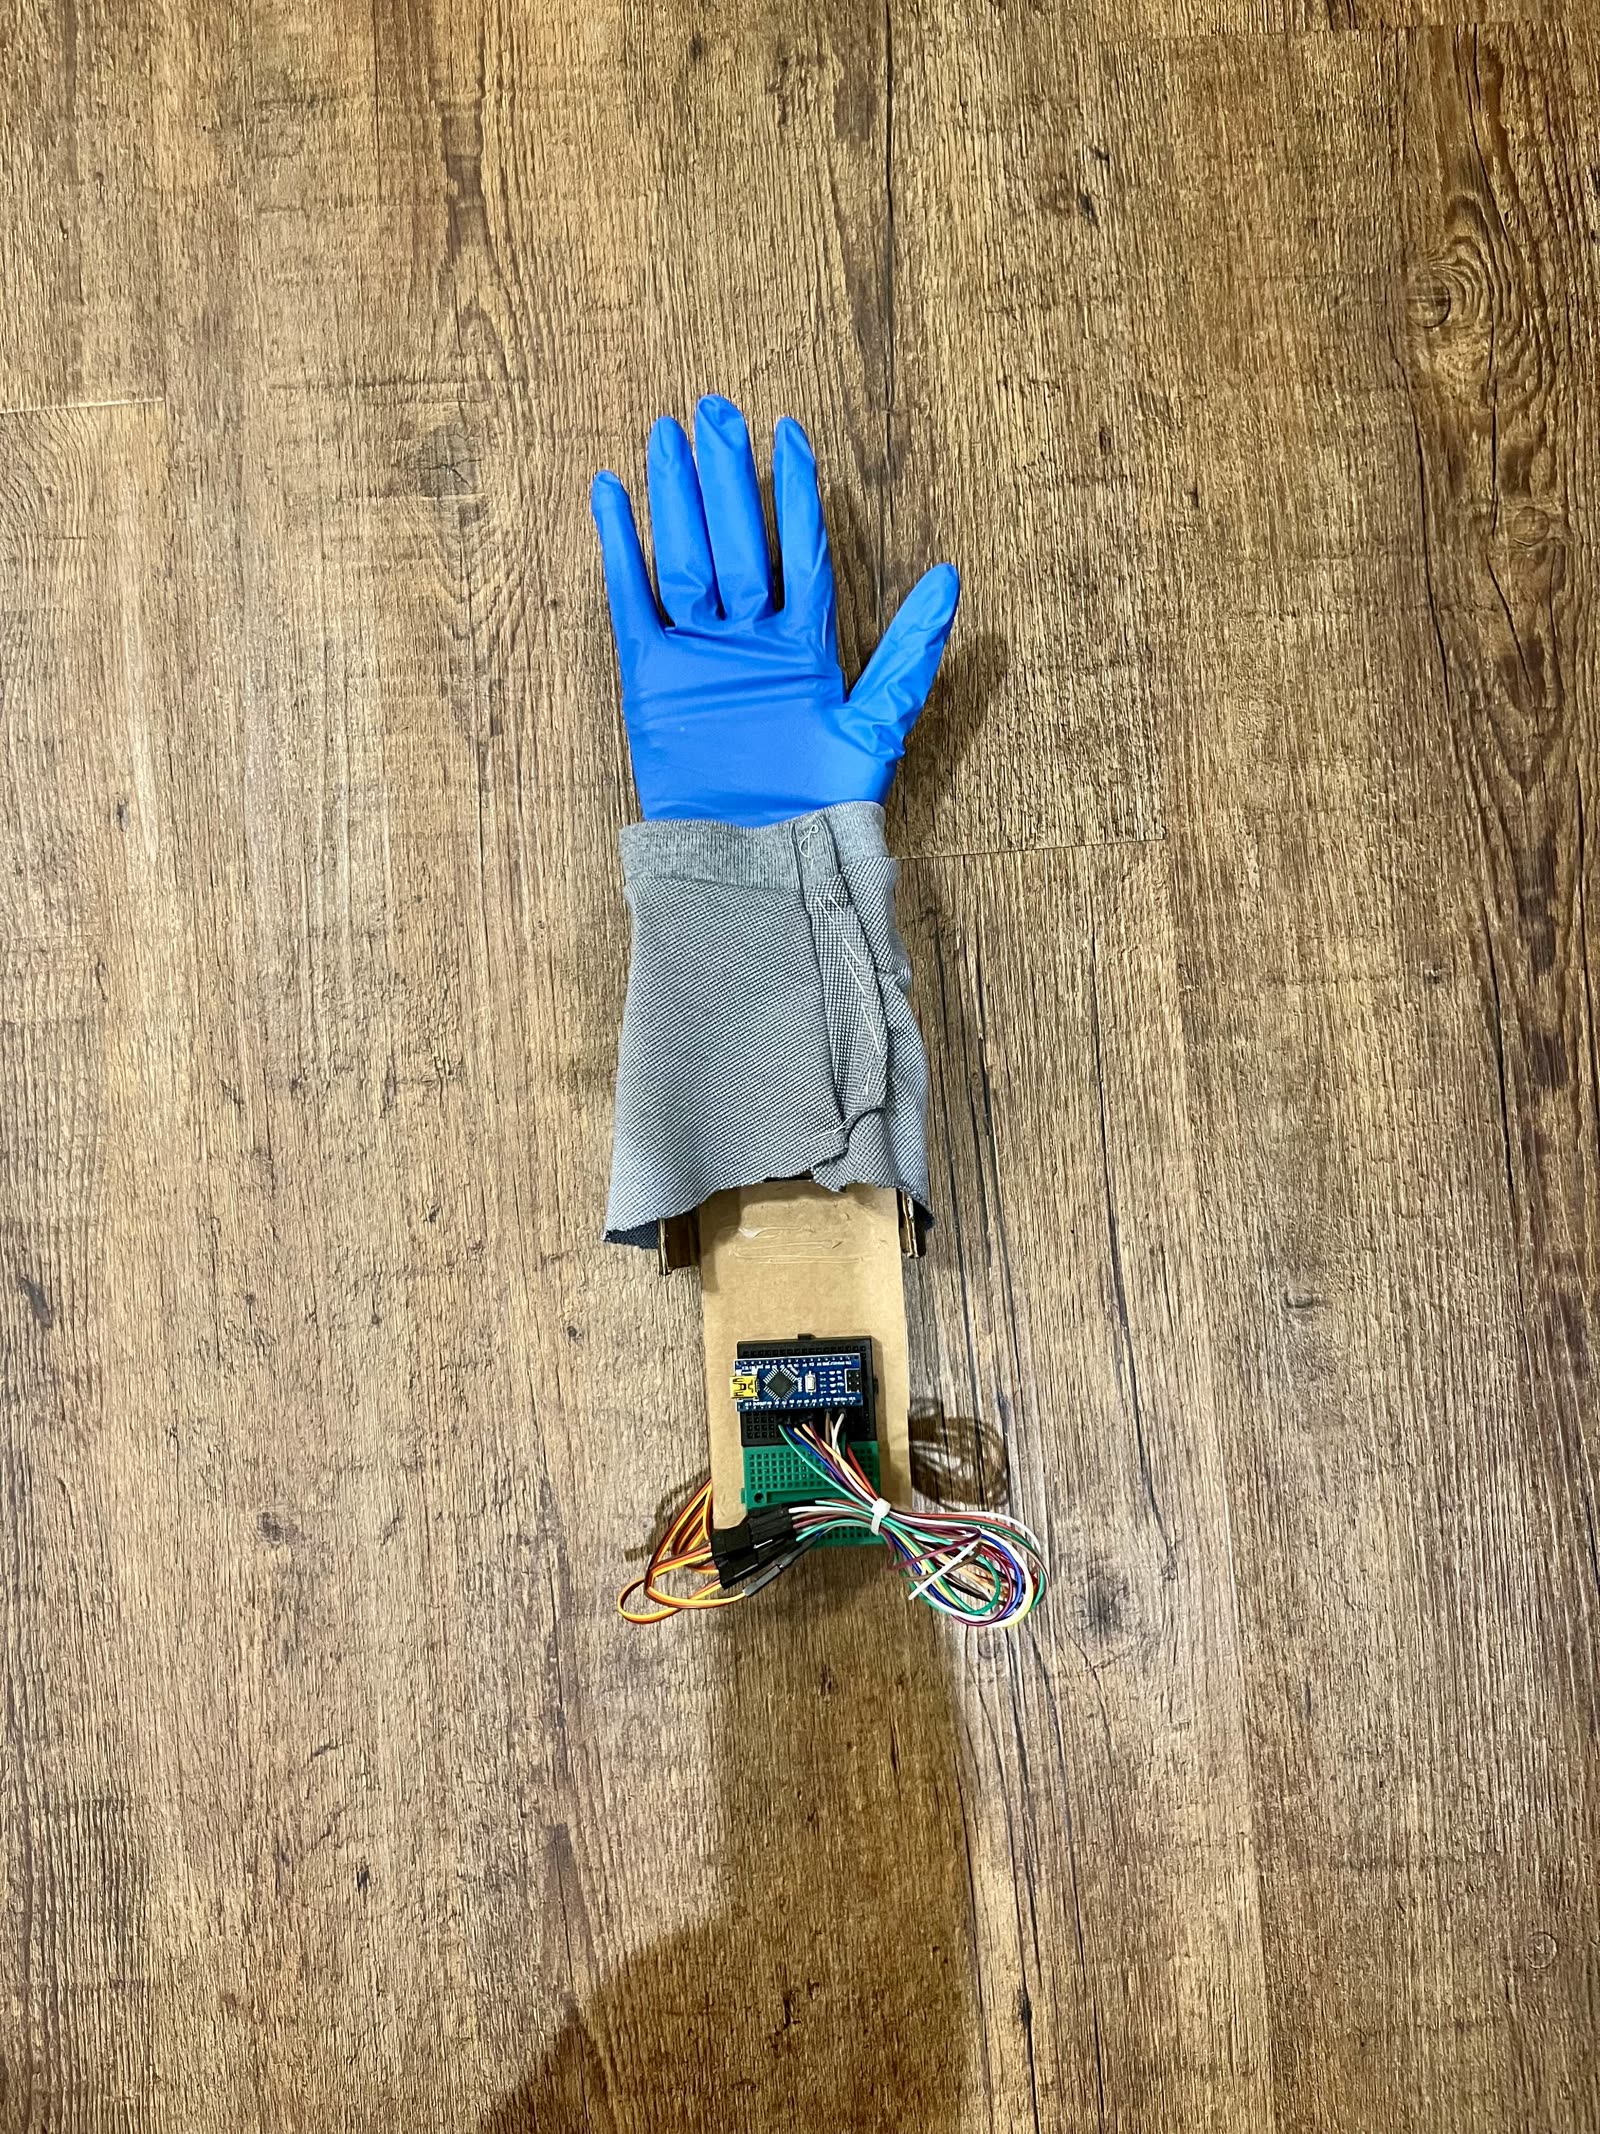
A summer project exploring beginner Arduino and electronics, built around SG90 micro servos and a fishing-line tendon system.
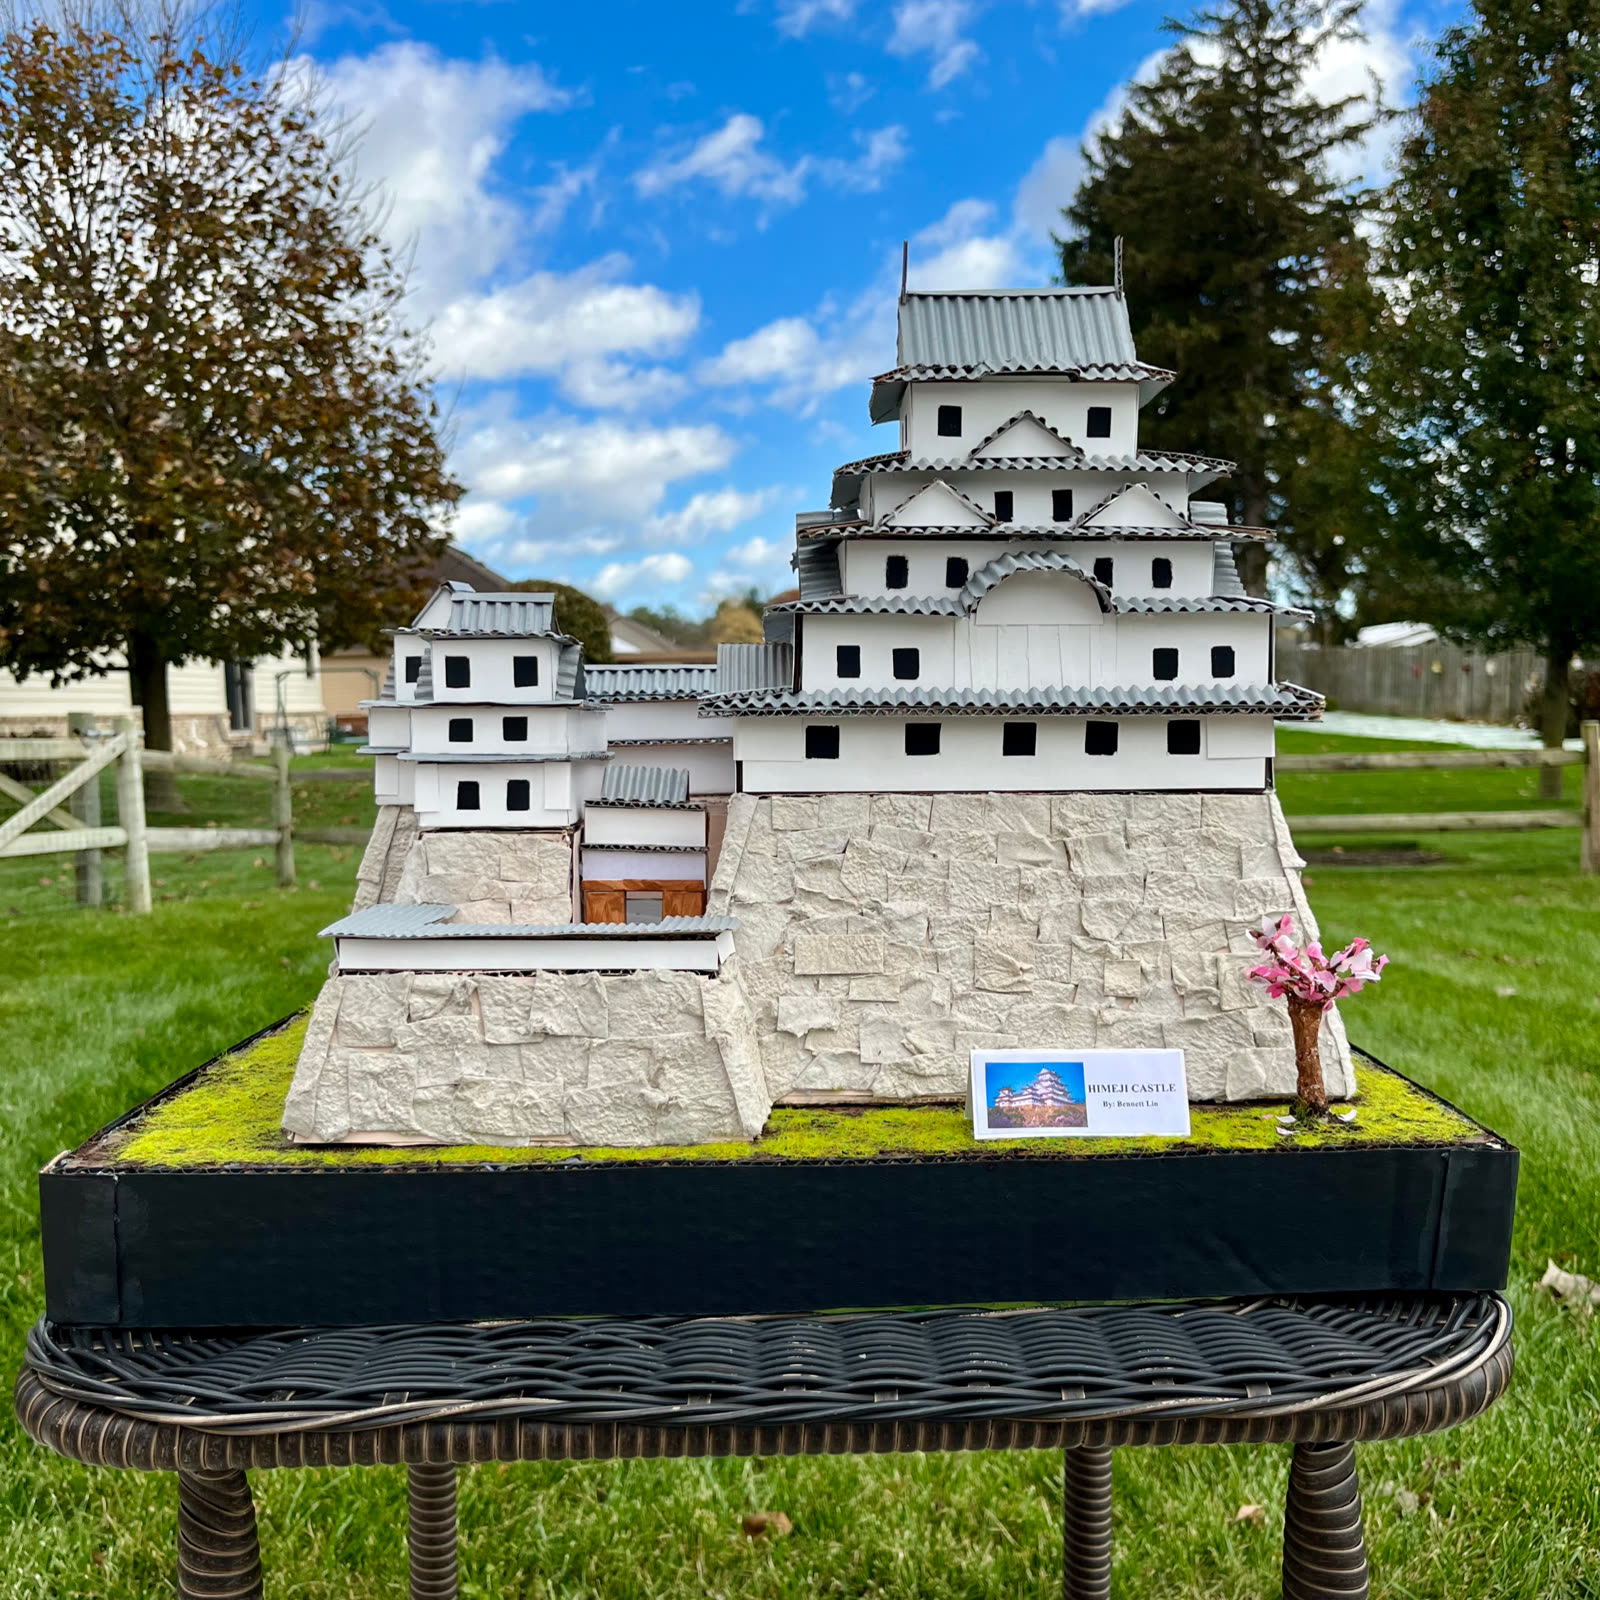
A dimensional analysis and art project scaling and constructing a cardboard model of Himeji Castle from the ground up.
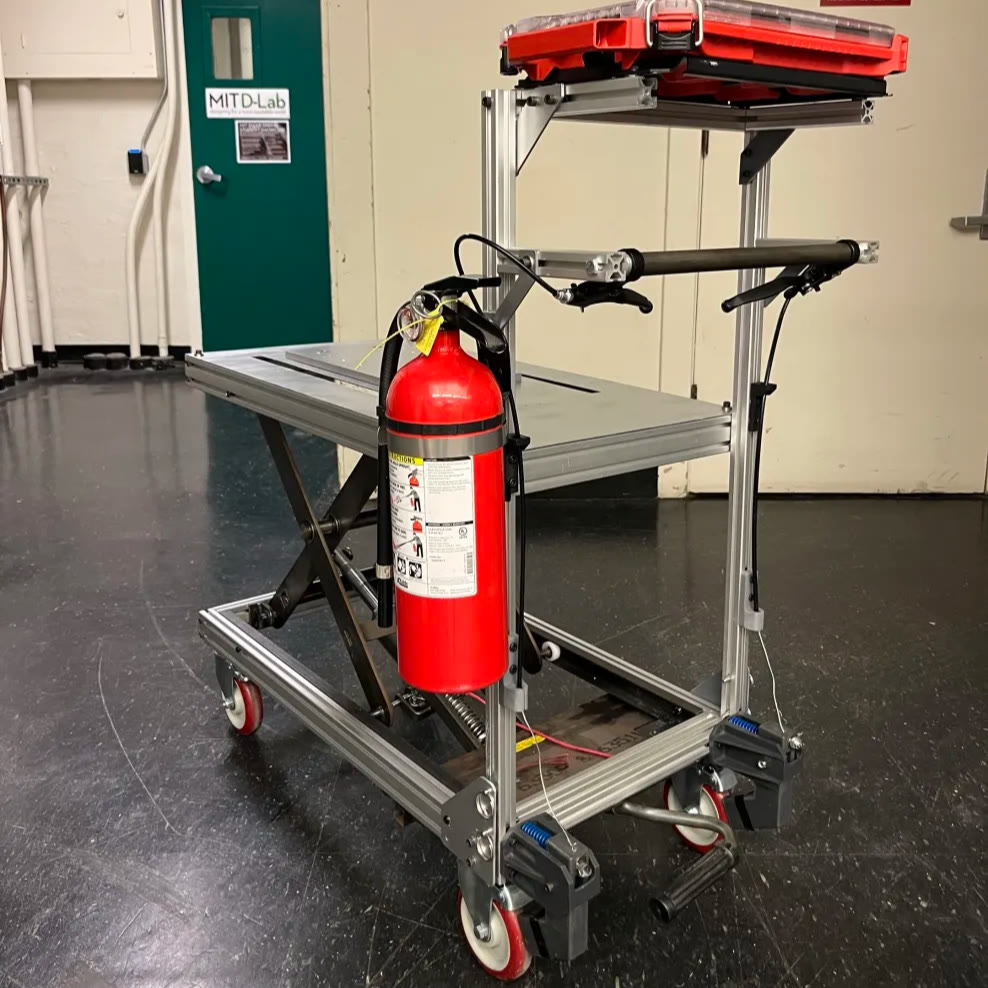
A mobile battery service cart for MIT FSAE Motorsports, with a hydraulic scissor lift and custom deadman brake system.
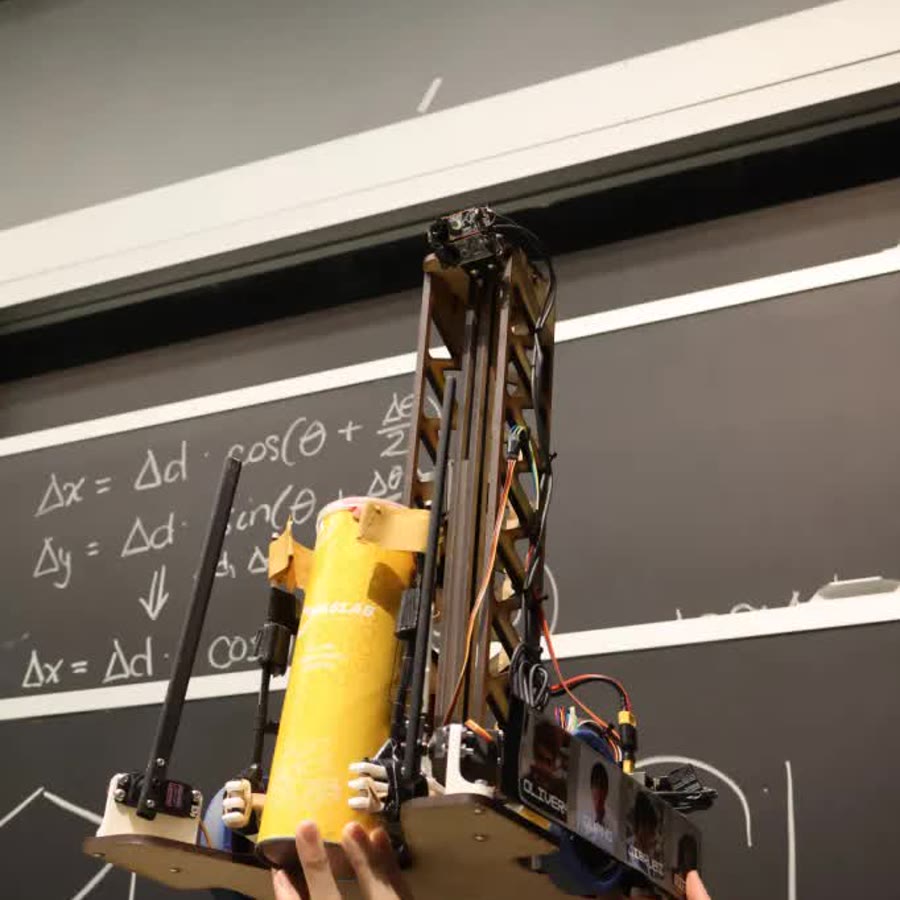
An autonomous robot for MIT's MASLAB competition, with a 3D-printed gripper and dual-camera object tracking.
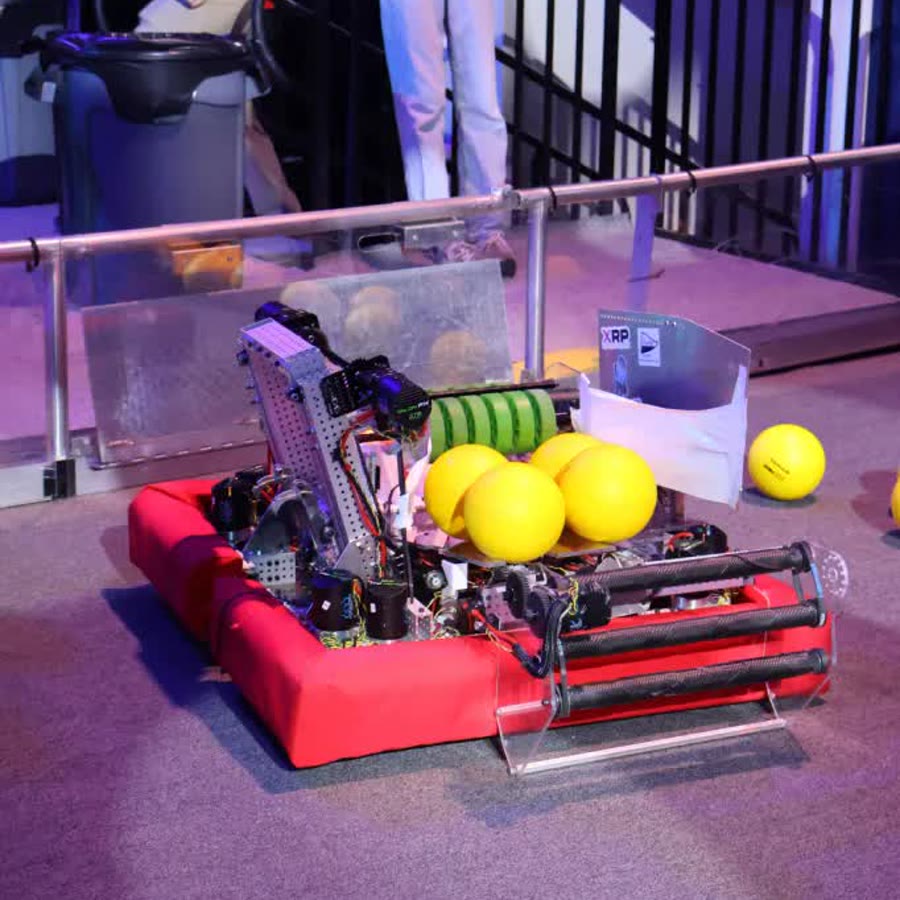
A robot built in three days at MIT's Robot in 3 Days event, rapid-prototyped for high school robotics teams to learn from.
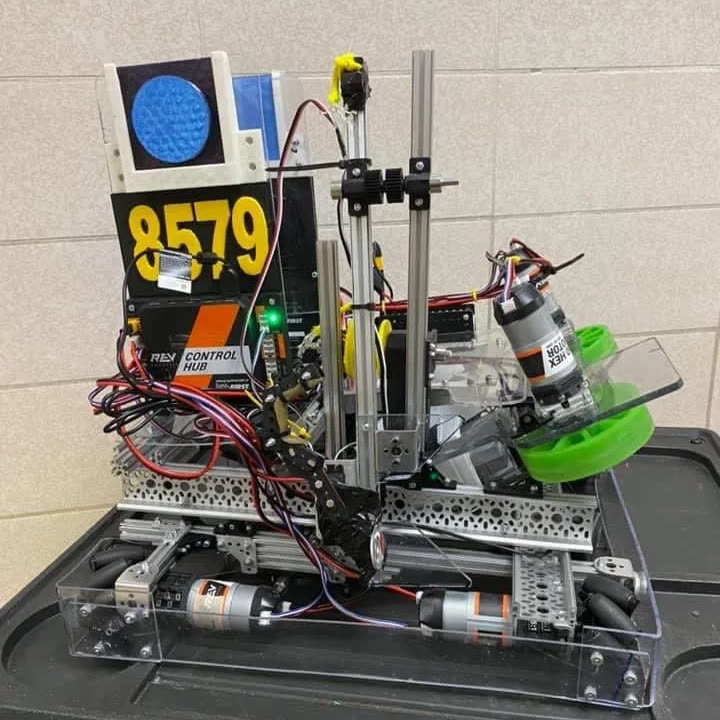
An omni-directional FTC robot with a star-wheel intake, zip-tie conveyor, flywheel shooter, and winch-driven capstone arm.
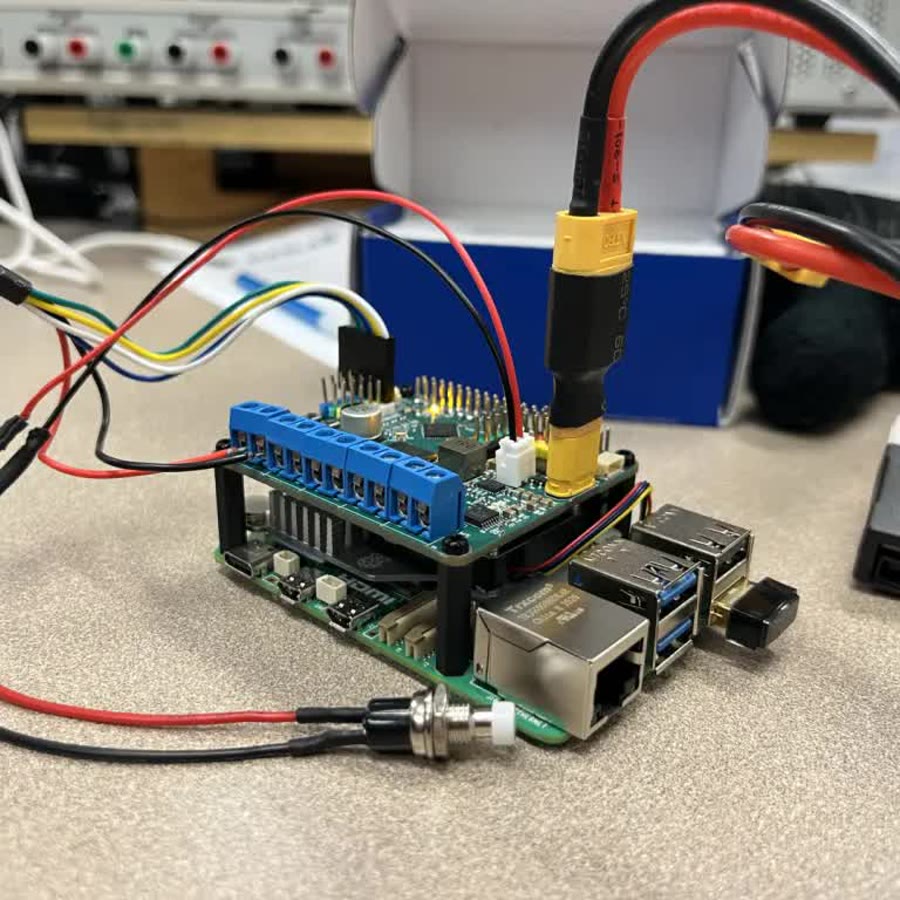
An object detection and tracking project built with Ultralytics YOLOv11.
 Bennett Lin