 Bennett Lin
Initial Design
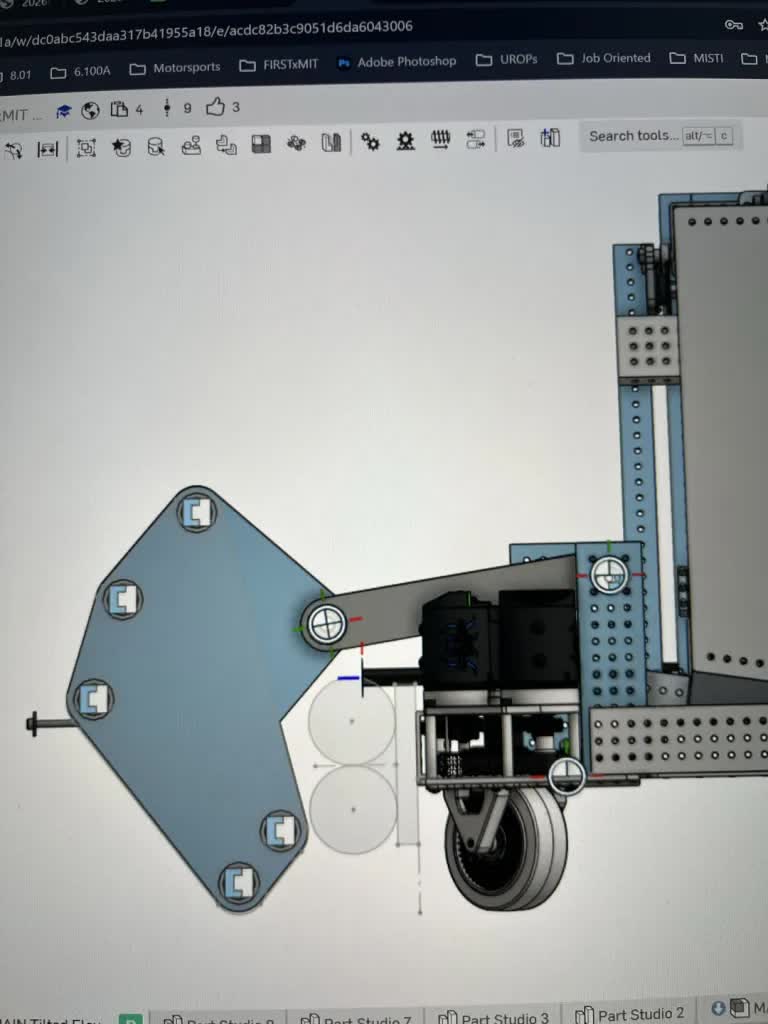
I was part of designing and doing hand calculations for intake compression. Intake rollers were polycarbonate 2 inch tubes attached to 3D-printed pulleys that connected to a belt system driven by a Kraken motor on the intake, a conventional 2 bar linkage intake.
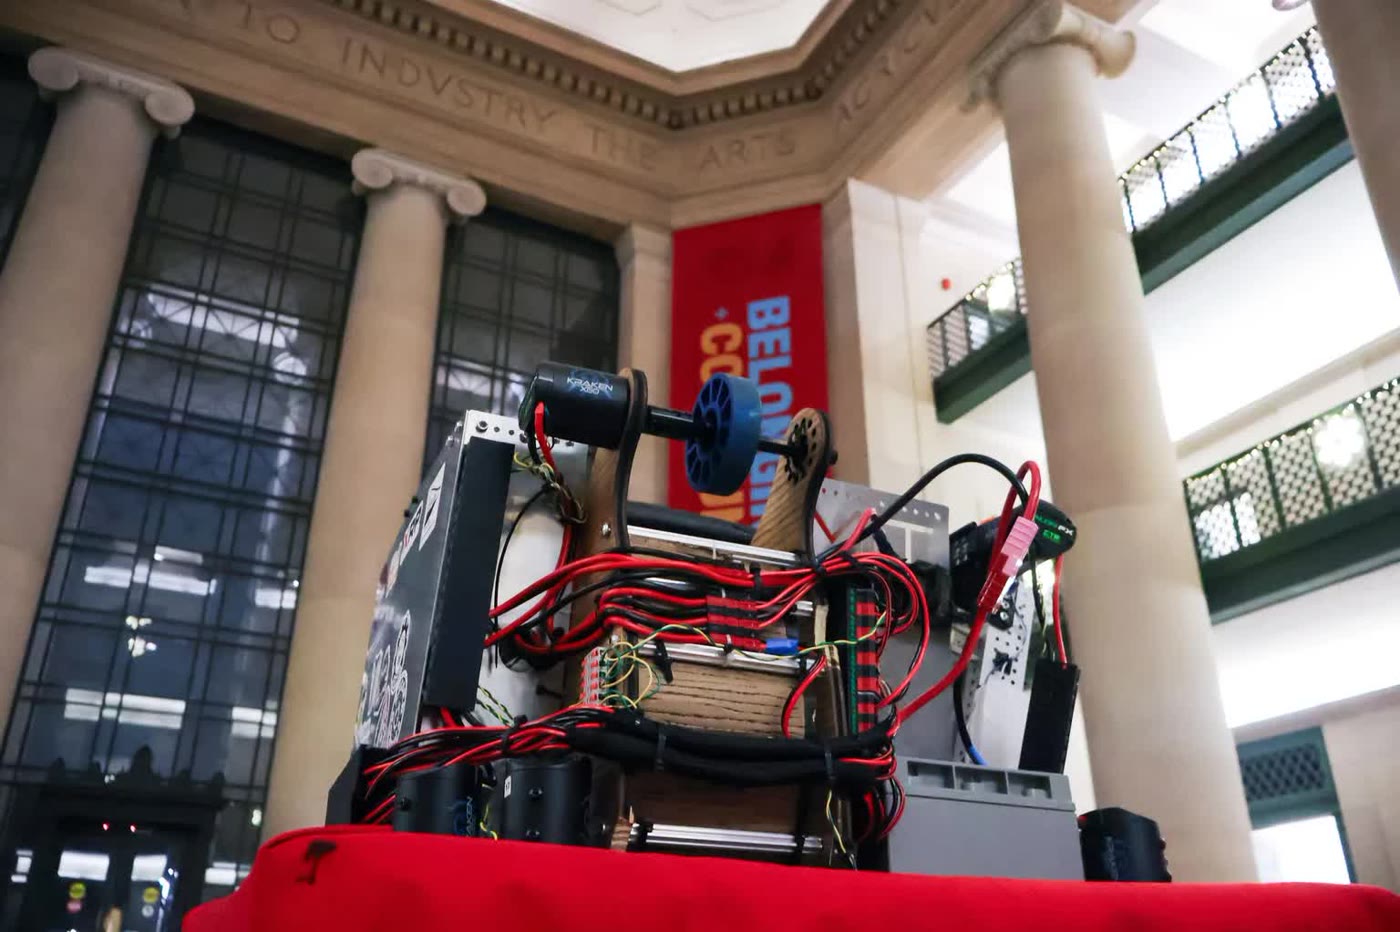
I also did the entire electrical wiring for the robot. However, issues came up as we designed the hopper with minimal packaging in mind, therefore unsafe electrical wiring techniques were used, as the wires were exposed on the outside.
Iteration for Governors Cup
FIRSTxMIT were invited to the inaugural Governors Cup and were asked to showcase our robot, therefore decided to iterate on it to be more reliable. Designed the entire shooting and hopper system, letting all the electronics sit below the hopper and doing shooting angle calculations to shoot at a steeper height, due to the showcase only providing a partial field. 4 inch compliant wheels were used to shoot, with 3D-printed ramps.