 Bennett Lin
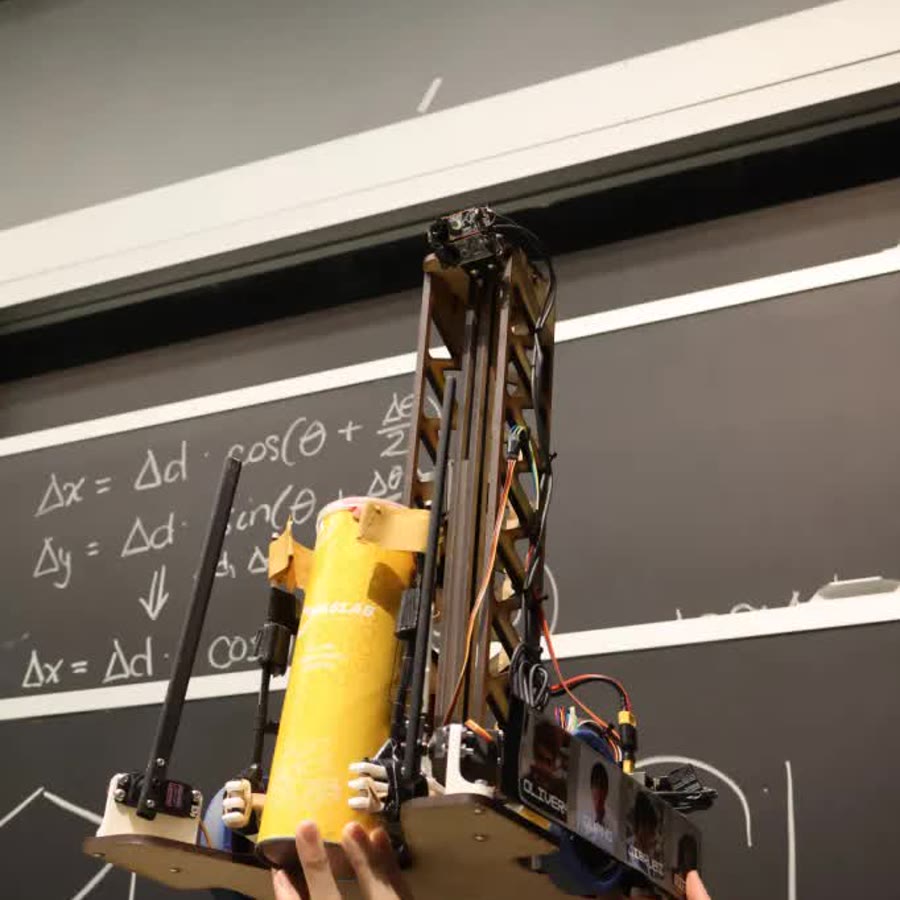
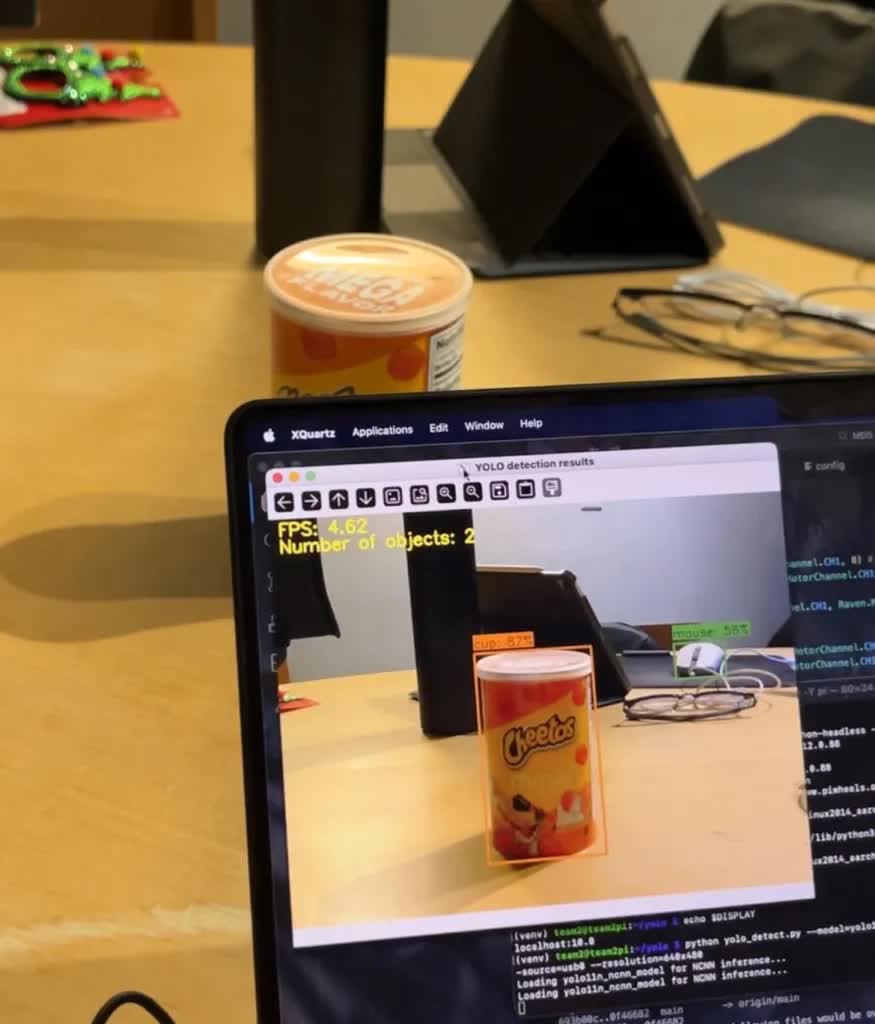
Claw initial prototype, before being 3D-printed and iterated upon.
Finished Robot
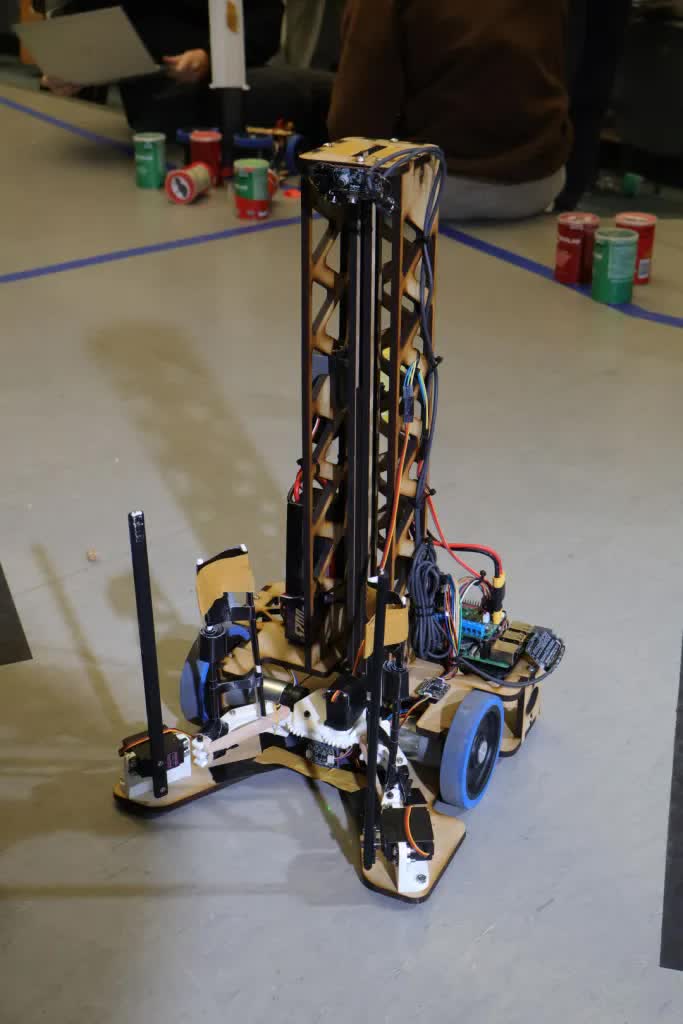
Continuous servo with a gear drove the rack and pinion elevator with an extended claw design to hold cans to stack. Had two 10.25 inch extending arms to catch cans at the start of the round.
Robot scoring during a match.