 Bennett Lin
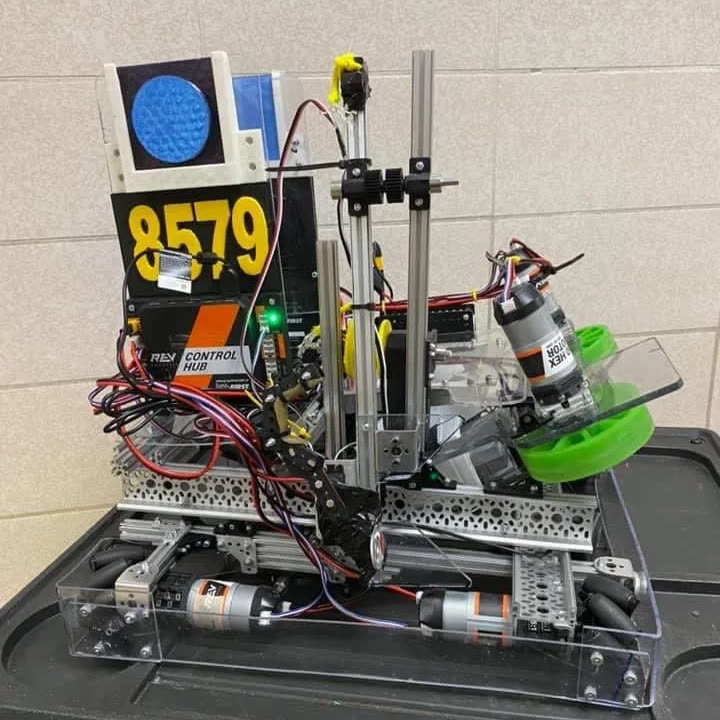
Designed the omni-directional chassis out of aluminum extrusion frames, giving the robot full strafing mobility around the field. The intake used trimmed-down star wheels to pick up the rubber scoring rings (game pieces) off the floor, feeding them into a conveyor system built from extruded zip ties sized to the width of the ring.
Capstone Mechanism
Capstone manipulation was handled by a simple pivot arm with a rope run to a winch, which pulled the capstone off the ground once a servo-actuated clamp secured it.
Flywheel Shooter
The conveyor carried each ring forward into a pair of 4-inch diameter compliant flywheels, which spun up and shot the ring across the field into the scoring zones.