 Bennett Lin
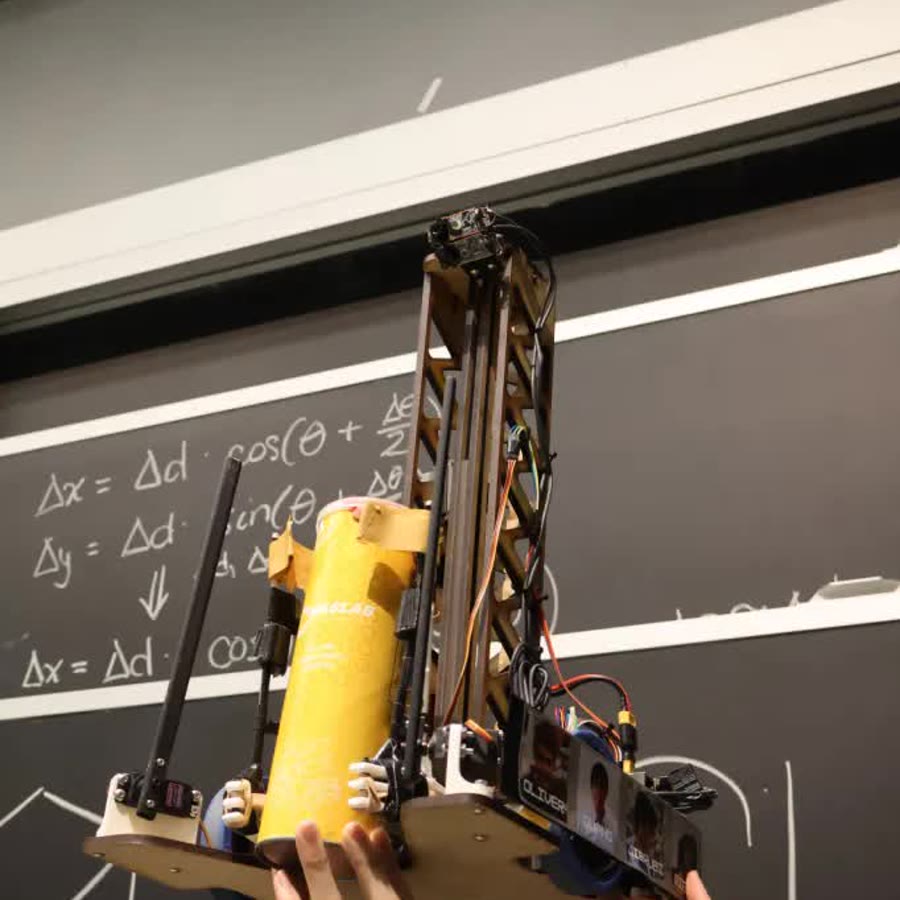
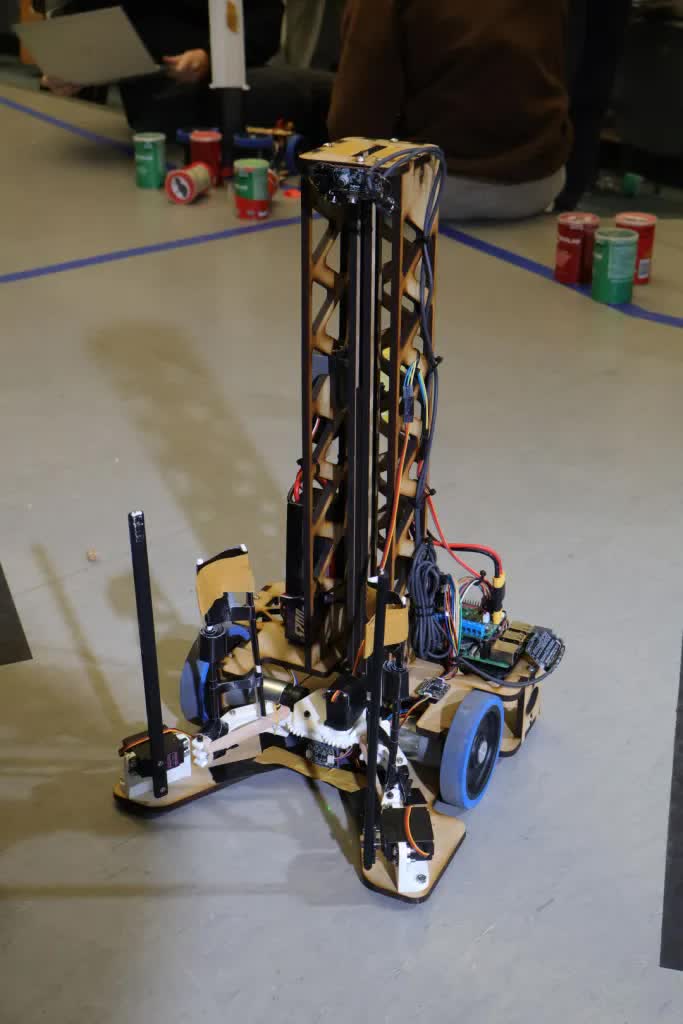
Finished Robot
Engineered the architecture for a competition-winning autonomous robot through custom frame geometry, interlocking assembly tabs, and electromechanical packaging optimized for uniform robot motion and 2 m/s field navigation.
Designed a rack-and-pinion elevator, gear-driven claw, and servo-actuated extending arms for maximized game-piece retrieval.
Continuous servo with a gear drove the rack and pinion elevator with an extended claw design to hold cans to stack. Had two 10.25 inch extending arms to catch cans at the start of the round.
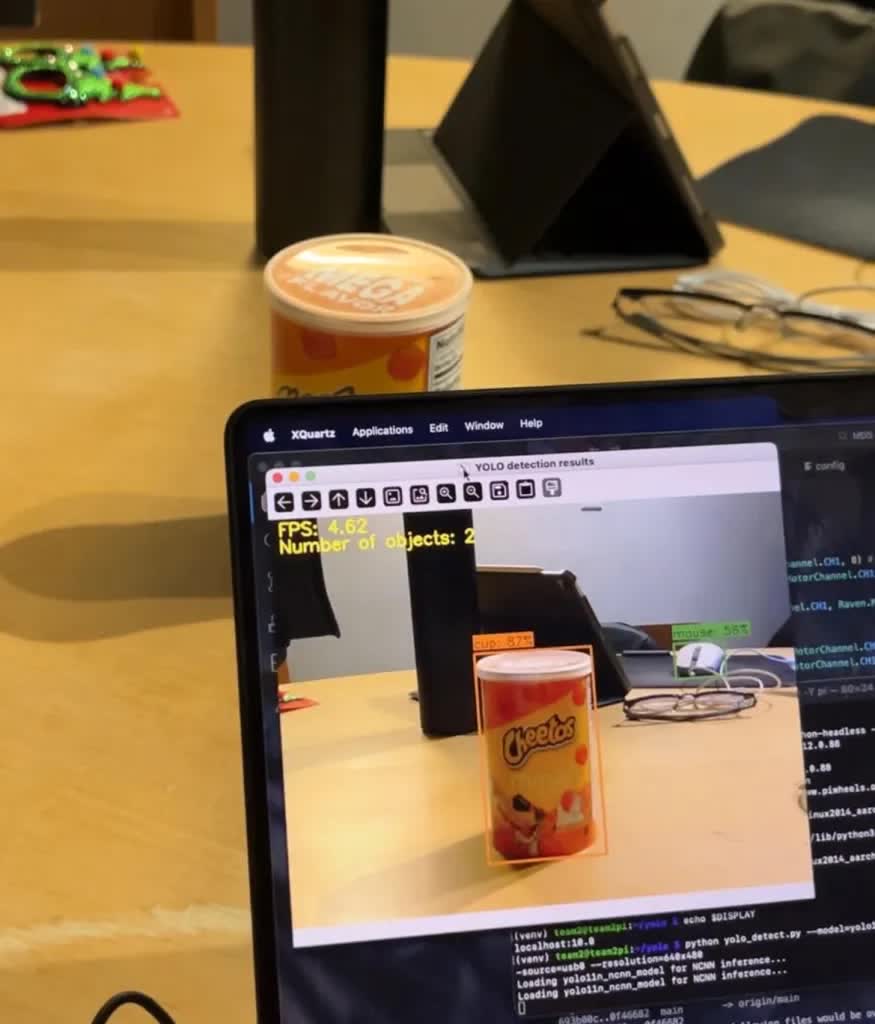
Vision
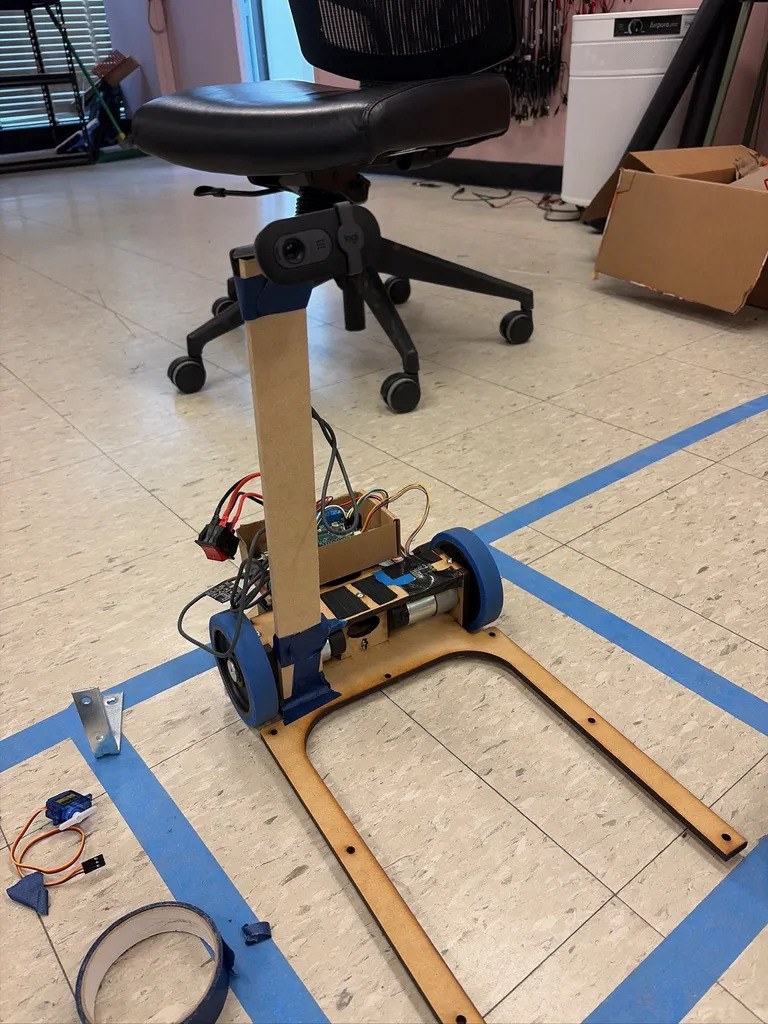
Designed a simple chassis to mimic the extending arms and the height of the camera for detection.
Initial object detection and odometry.
Detecting cans (game piece) with YOLO.
Claw Prototype
Claw initial prototype, before being 3D-printed. Rubber bands were wrapped to provide grip, and the 3D-printed claw model used 2 long rods wrapped to create a light net design meant to stack 2 cans.
Elevator Testing
Initial testing for rack and pinion elevator.
Stacking & Scoring
Robot stacking cans.
Robot scoring during a match.